Automation / Robotic machine tending
LoadAssistant · with FANUC robot
Robotic machine tending cells
Mobile, modular loading robots with a 6-axis FANUC arm for CNC lathes and milling machines. While the robot works from one side, the operator loads the other side, with no downtime.
9
models, one user interface
1000+
HALTER robots in 30+ countries
< 5 min
new batch setup
15–30 min
relocation to another machine
4 machines
tended by one robot
In action
How the HALTER LoadAssistant works.
The 3-minute video with Hungarian subtitles shows how to operate the cell, how to prepare a new batch and the robot at work.
Models
Nine models, one user interface.
Grid plate (Basic Pro, Universal) or stacker (TurnStacker, MillStacker) versions, depending on the workpiece. The models differ in FANUC robot payload and capacity, and all of them run on the HALTER SmartControl control system.
Grid plate loading robots for lathes and milling machines: for mixed workpieces, with optional shaft handling. Select a model for detailed specifications.
Entry-level model
Basic Pro 12
Entry-level model for one machine; a floor scanner instead of a fence protects the operator.
Request a quoteKey data
Robot (FANUC) payload
12 kg
Workpiece diameter
Ø10–135 mm
Square parts, max.
135 × 135 mm
Workpiece height
10–200 mm
Shaft handling
–
Loading table
grid plate, max. 360 kg
Parts / grid plate, up to Ø35 mm
104 pcs
Footprint (L × W)
1710 × 780 mm
Parts / grid plate, by diameter
Ø10–20 mm
173 pcs
Ø10–35 mm
104 pcs
Ø10–55 mm
64 pcs
Ø10–85 mm
31 pcs
Ø10–115 mm
22 pcs
Ø10–135 mm
14 pcs
Dimensions and connections
Height
2200 mm
Net weight
650 kg
Connections
400 V, 16 A, 6.5 bar
Transport
with pallet jack
New · HALTER Modular
A cell tailored to your production.
HALTER Modular is not a fixed model but a cell built from modular components: we select the layout, material supply, gripping, safety system and robot to suit your production process.
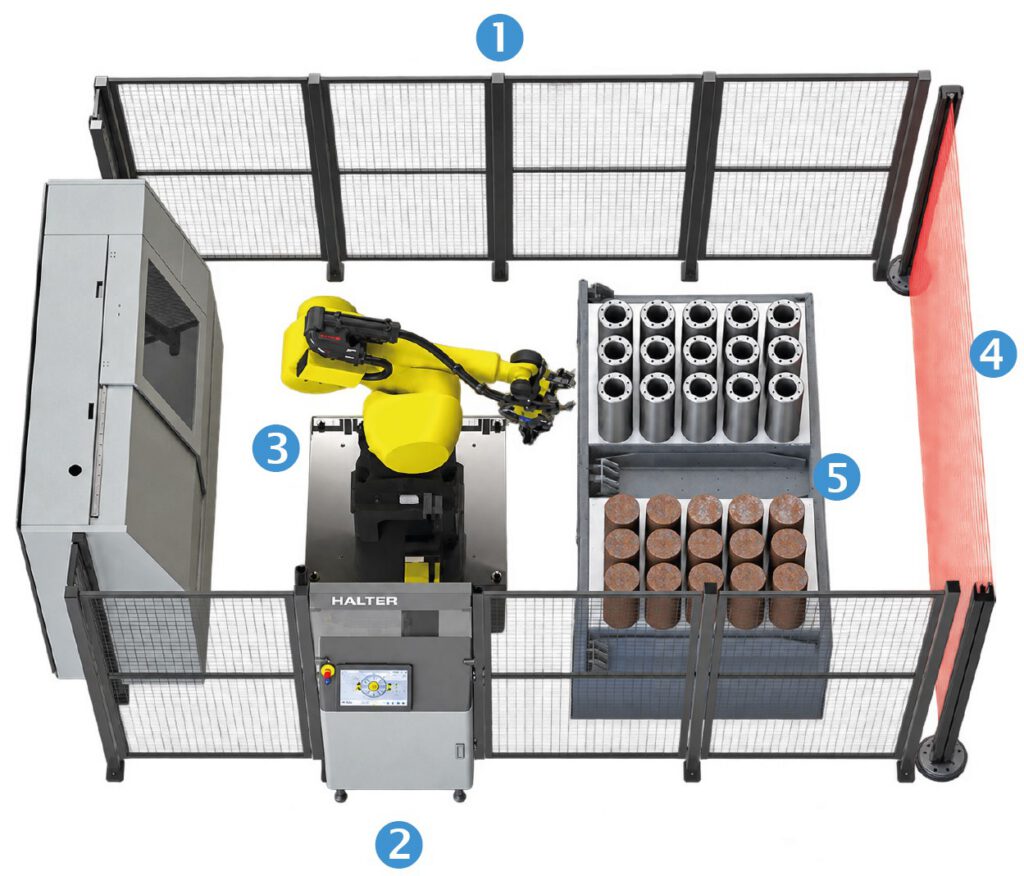
01
Modular cell design
The layout adapts to your existing machines and the available space.
02
HALTER SmartControl
Guided setup and fast changeover, with the same user interface as the LoadAssistant models.
03
Industrial robot platform
FANUC robot with 35, 70 or 165 kg payload, built from proven industrial components.
04
Configurable safety
Fencing, doors, light curtain or laser scanner, depending on the cell layout.
05
Flexible material supply
Pallet, cart, conveyor, table or AGV/AMR, matched to your existing material flow.
Layouts
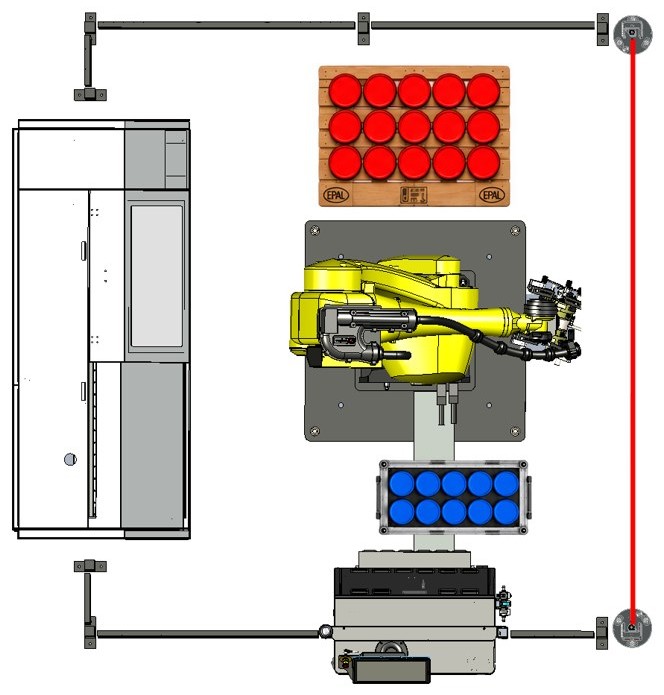
Compact
Robot, machine and material supply on the smallest possible footprint.

Conveyor
Raw and finished parts arrive and leave on a conveyor.
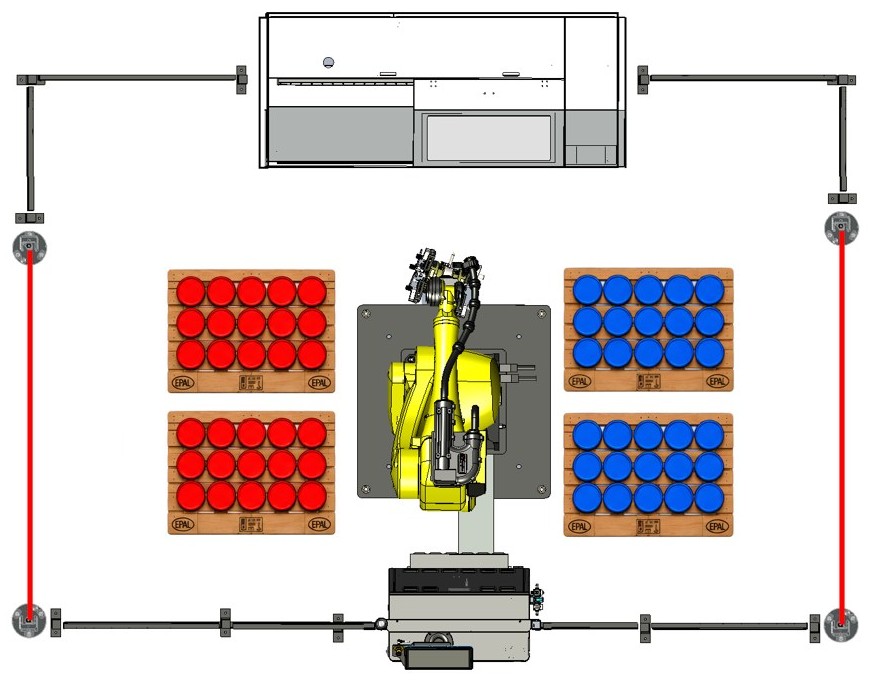
Multi-pallet
Multiple pallets in the cell: larger buffer, longer unattended production.
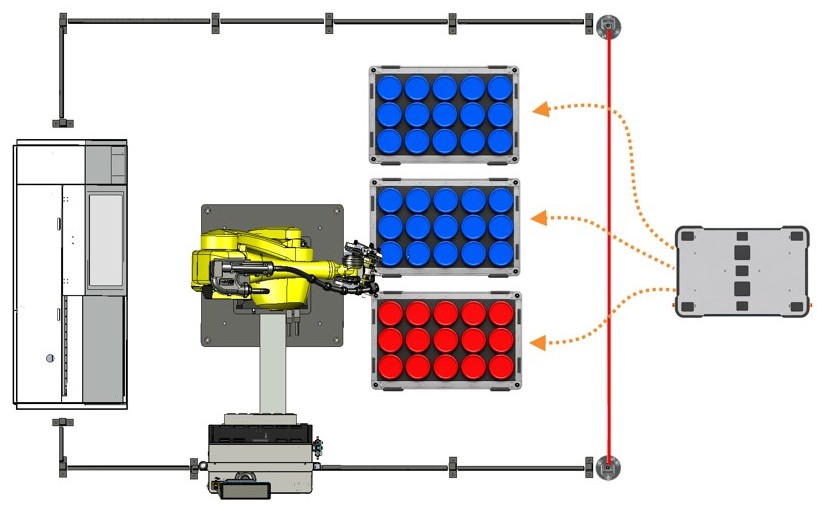
AGV / AMR
A mobile robot brings and removes the pallets, making the cell part of the plant's material flow.
Pallet strategies
Fixed: separate pallets for raw and finished parts
Mixed: raw and finished parts on a shared pallet
Dynamic: automatic slot allocation on the pallets
Gripping
Centric and parallel grippers
Shaft gripper
Magnetic gripper
Custom, part-specific gripper
Robot and safety
FANUC robot: 35, 70 or 165 kg
Fencing and doors
Light curtain
Laser scanner
Functions
More than loading and unloading.
With the optional SmartControl functions, the robot also takes over the manual steps around machining. We recommend the right combination based on the workpiece and the machine.
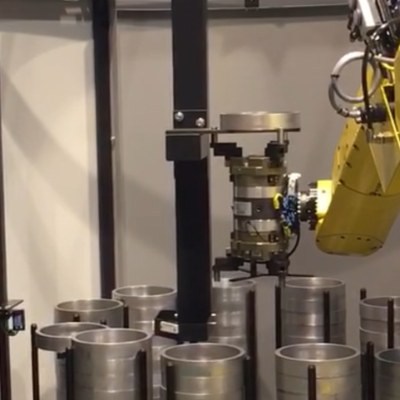
Flipping for two-sided machining
After the first side, the robot flips the part and reloads it for the second operation.

Unloading onto pallets
For a larger buffer or heavy parts, finished parts are placed on pallets.
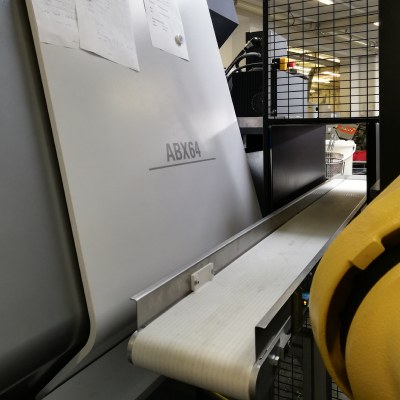
Unloading to an external location
For example onto a conveyor, toward the next operation or packaging.

Pickup from the turret
The robot takes the workpiece from the clamping device in the turret.

Cleaning outside the machine
The part returns clean to the grid plate or the measuring station.

Measuring station
The robot places the part on a measuring station and sorts rejects to a separate location.

Shaft handling
Shafts up to 600 mm with a standard grid plate, up to 1000 mm with a custom grid plate.
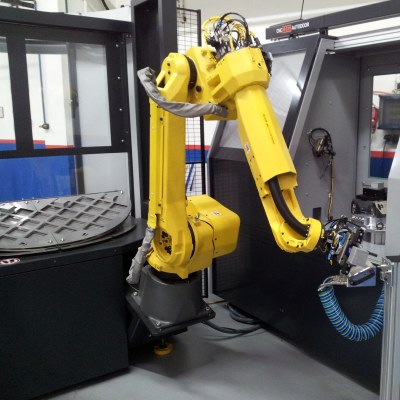
Custom functions
Part-specific grippers, grid plates and program functions on request.
From the manufacturer
Detailed specifications and datasheets for all HALTER models (Basic Pro, Universal, Modular) on the manufacturer's website.
More automation
The right solution for the task.


Which HALTER fits your machine?
Send us your machine type and workpieces. We will get back to you within 1 day with a recommendation and a payback calculation.
CNC machine accessories, tooling and automation for machining shops: sales, installation, service.
CNC machine accessories
Contact
Prevotex Hungary Kft.
Vegyész utca 19–25, 1117 Budapest, Hungary
© 2026 Prevotex Hungary Kft. All rights reserved. Product and brand names are the property of their respective manufacturers.
Imprint · Privacy policy · Cookie policy